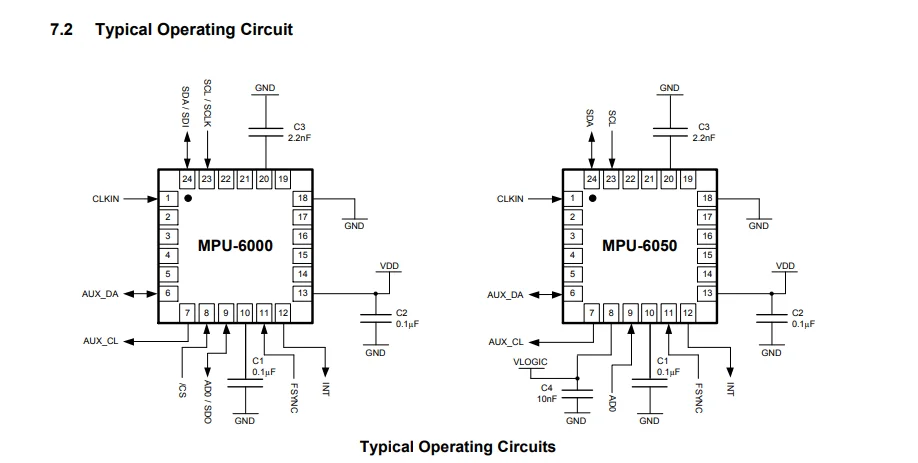
In the realm of technological intricacies, where information converges into the blueprint of innovation, lies a crucial facet often overlooked yet indispensable: the compendium of dynamic intelligence. Delving into the essence of this compendium unveils a labyrinth of insights, a roadmap to decipher the language of precision instruments, a portal to the realm of meticulous craftsmanship.
Within these pages, one finds not mere words but a symphony of technical elucidation, a narrative of functionality intertwined with design intricacies. It is the codex that breathes life into circuits, infusing algorithms with purpose, and bestowing upon sensors their raison d’être.
Herein lies the gateway to understanding the heartbeat of innovation, where each line is a thread weaving the fabric of progress. Beyond the syntax and semantics, it is a testament to human ingenuity, a testament to the ceaseless quest for precision in an ever-evolving technological landscape.
Gyro Specifications Deciphered
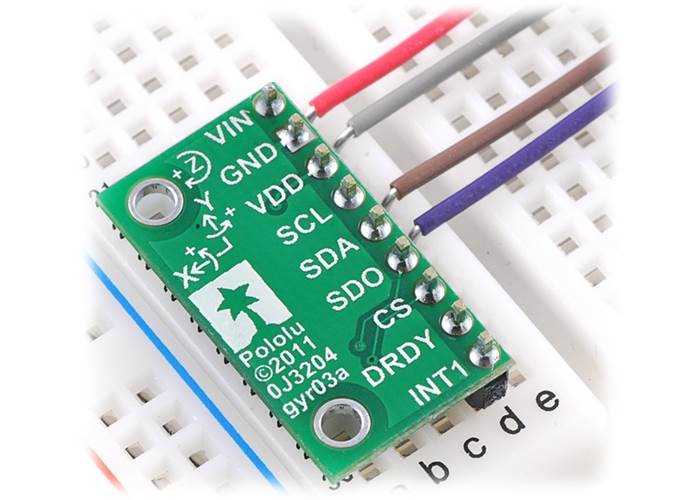
Delving into the intricate details of a gyro’s technical documentation can be akin to deciphering a complex puzzle, where each specification holds a key to understanding its performance and capabilities. In this section, we embark on a journey to unravel the nuances of gyro specifications, shedding light on the crucial parameters that define its behavior and functionality.
The Language of Precision
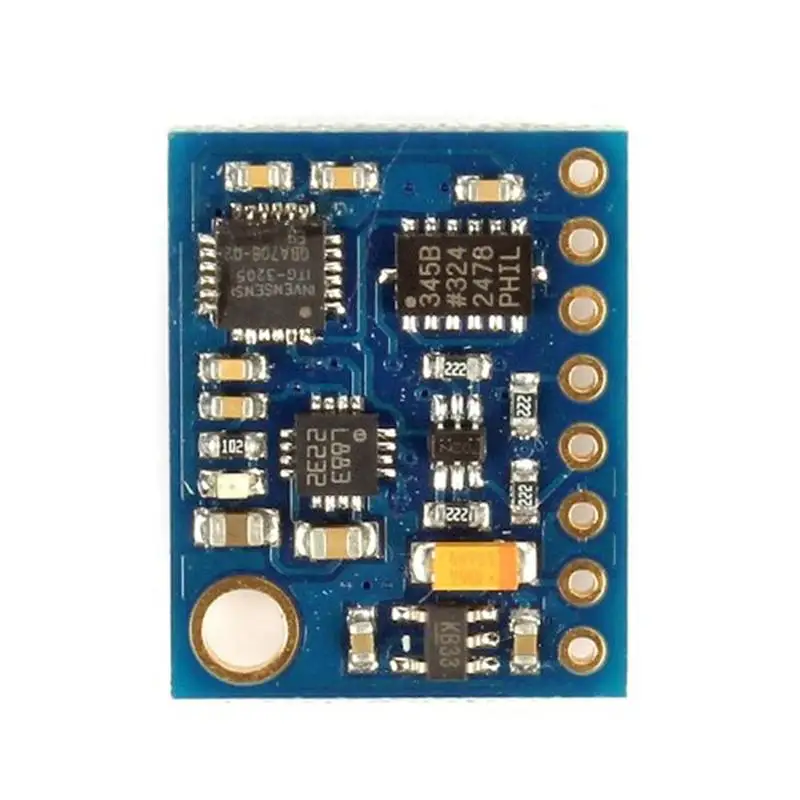
Embedded within the labyrinth of specifications lie the language of precision, where terms like sensitivity, bias stability, and bandwidth serve as signposts guiding us through the gyro’s intricacies. Each specification delineates a facet of the gyro’s performance, offering insights into its responsiveness, accuracy, and reliability.
Interpreting Performance Metrics
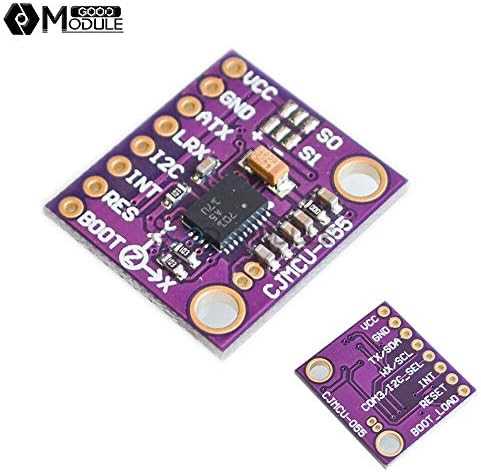
As we navigate through the datasheet, we encounter an array of performance metrics, each carrying profound implications for the gyro’s real-world application. From dynamic range to noise characteristics, these metrics paint a comprehensive picture of the gyro’s capabilities, empowering engineers to make informed decisions in system design and integration.
In our quest to comprehend gyro specifications, we delve beyond the surface-level numbers, unraveling the underlying principles that govern its operation. By deciphering these specifications with diligence and insight, we unlock the full potential of the gyro, harnessing its capabilities to drive innovation and advancement in diverse fields of technology and engineering.
Deciphering Key Parameters
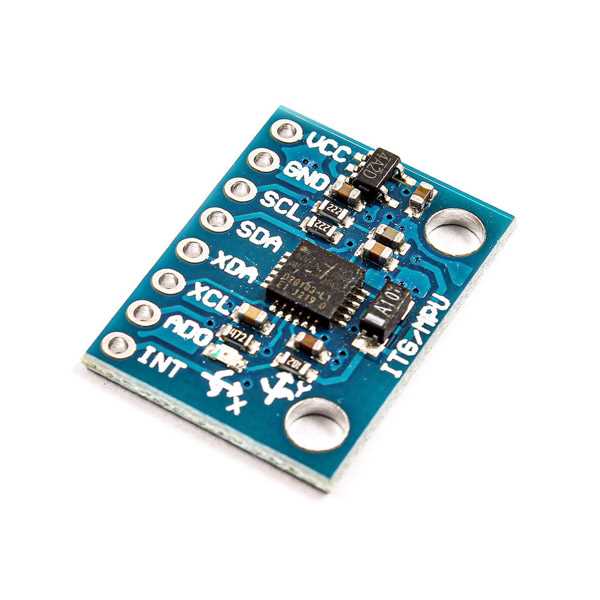
Within the intricate labyrinth of technical specifications lies a wealth of critical information, guiding the understanding and utilization of the gyroscopic device. Delving into the intricacies of its operational dynamics requires a comprehensive grasp of essential indicators, each carrying nuanced significance in the realm of motion sensing technology.
1. Sensitivity and Resolution
The sensitivity and resolution metrics serve as the bedrock for assessing the device’s responsiveness and precision in detecting minute changes in orientation or angular velocity. These parameters illuminate the device’s ability to discern subtle shifts in motion, crucial for applications demanding fine-tuned accuracy.
2. Bias and Drift
Bias and drift encapsulate the inherent tendencies of the device to deviate from its intended output over time or under specific conditions. Understanding these characteristics is pivotal for calibrating the gyroscopic system and mitigating the impact of environmental factors, ensuring consistent and reliable performance across diverse operating environments.
- Bias: Reflects the systematic error inherent in the device’s measurements, often stemming from manufacturing imperfections or environmental influences.
- Drift: Signifies the gradual change in output over time, attributed to factors such as temperature variations, component aging, or external disturbances.
By unraveling the nuances embedded within these key parameters, practitioners can navigate the intricacies of gyroscopic technology with precision and confidence, unlocking its full potential across an array of applications spanning aerospace, robotics, and beyond.
Interpreting Performance Metrics
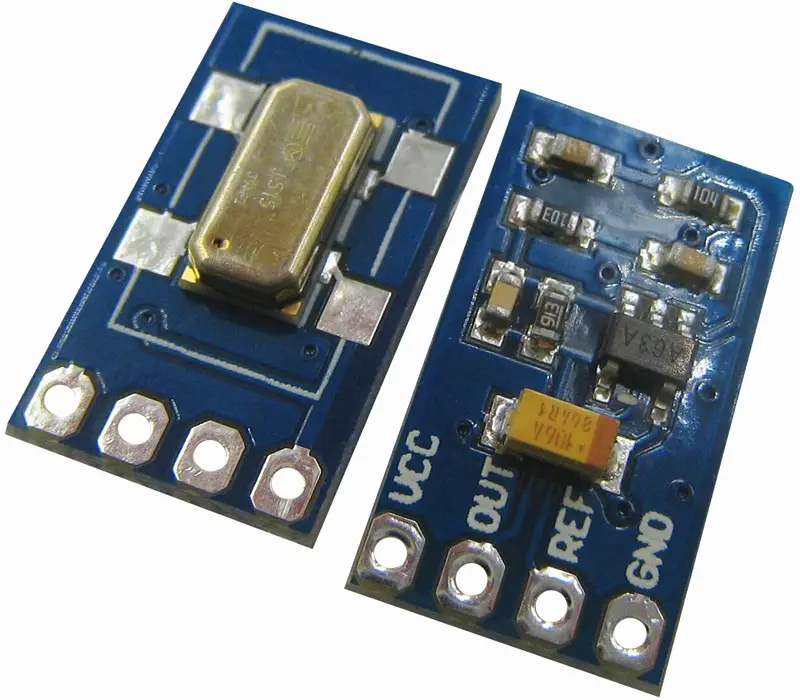
Understanding the intricacies of the data presented in the performance metrics section is paramount for comprehending the operational capabilities of the device in question. This segment serves as a guide to decode the various indicators provided, shedding light on the functionality and efficiency of the examined system.
Accuracy Assessment: Within this evaluation, the precision of the measurements is scrutinized, offering insights into the device’s ability to provide reliable data points. The margin of error, consistency, and deviation from the true value are among the key aspects analyzed.
Response Time: This metric delves into the speed at which the device reacts to changes in input or environmental conditions. A swift response time is indicative of agility and real-time adaptability, crucial for dynamic applications.
Resolution: The resolution parameter delineates the smallest detectable change in the measured quantity. It elucidates the granularity of the data and influences the device’s capability to discern subtle variations, thereby affecting its overall sensitivity.
Drift: Drift elucidates the tendency of the device to deviate from its initial calibration over time. Understanding the drift pattern is essential for long-term performance estimation and calibration maintenance strategies.
Noise: Noise refers to unwanted variations or disturbances present in the measured signal. Evaluating noise levels aids in distinguishing true data from interference, ensuring the reliability and accuracy of the output.
Bandwidth: Bandwidth delineates the range of frequencies over which the device can accurately capture and process data. A broad bandwidth signifies versatility in handling diverse signal frequencies, catering to a wide array of applications.
Dynamic Range: The dynamic range encompasses the span between the minimum and maximum detectable values. It quantifies the device’s ability to capture signals of varying magnitudes, elucidating its adaptability to different operating conditions.
By deciphering these performance metrics with precision, users can glean invaluable insights into the capabilities and limitations of the device, enabling informed decision-making and optimal utilization.
Optimizing Inertial Sensor Integration: Practical Considerations
In the pursuit of seamless fusion between inertial sensors and electronic systems, understanding the intricacies of integration becomes paramount. This section delves into practical considerations aimed at refining the amalgamation of motion sensors with their host platforms. By exploring various strategies and techniques, we aim to enhance the efficiency and accuracy of sensor data utilization without compromising on system performance.
| Consideration | Description |
|---|---|
| Alignment Calibration | Ensuring proper alignment between the sensor axes and the reference frame is essential for accurate data interpretation. Calibration techniques such as sensor fusion algorithms or manual adjustments play a crucial role in achieving optimal alignment. |
| Temperature Compensation | Temperature fluctuations can significantly impact sensor performance. Implementing robust temperature compensation algorithms mitigates these effects, enhancing the sensor’s stability and reliability across varying environmental conditions. |
| Filtering Techniques | Effective filtering methods are indispensable for reducing noise and enhancing signal quality. Employing low-pass, high-pass, or Kalman filters tailored to specific motion characteristics aids in extracting meaningful information from sensor data streams. |
| Integration Time Optimization | Adjusting integration time parameters based on motion dynamics optimizes sensor responsiveness while minimizing power consumption. Striking a balance between integration time and sampling rate is crucial for achieving desired performance metrics. |
| System Calibration | Comprehensive system calibration, encompassing sensor biases, scale factors, and misalignment errors, is indispensable for accurate motion estimation. Employing advanced calibration techniques such as sensor fusion or in-field calibration routines enhances overall system accuracy. |
By incorporating these practical considerations into the integration process, developers can elevate the performance and reliability of inertial sensor applications across various domains, ranging from consumer electronics to industrial automation.
Hardware Compatibility and Integration
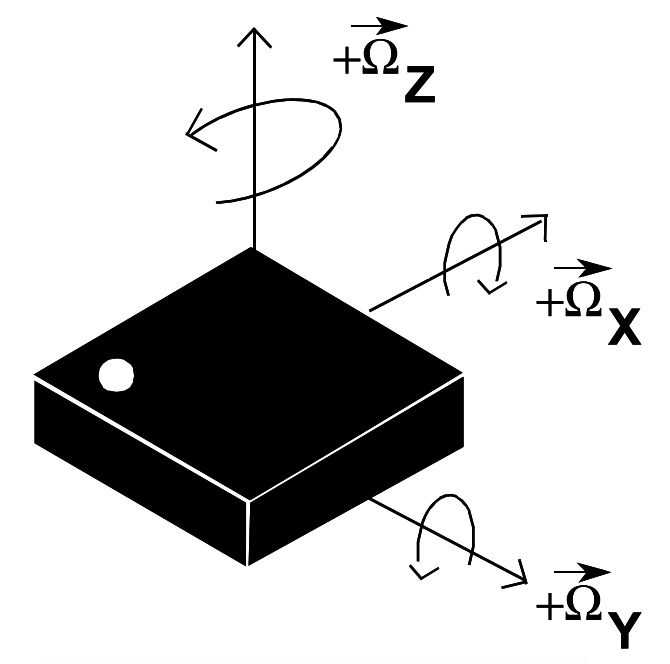
In this section, we delve into the seamless integration and compatibility aspects of the hardware components, ensuring a harmonious fusion between the gyroscopic sensor and its surrounding ecosystem. The successful amalgamation of diverse hardware elements forms the bedrock of optimal performance and reliability, transcending mere compatibility into a realm of synergistic cohesion.
| Component | Compatibility | Integration |
|---|---|---|
| Inertial Measurement Unit (IMU) | Ensuring alignment with specifications | Integrating sensor data seamlessly into IMU algorithms |
| Microcontroller | Compatible communication protocols | Efficient utilization of processing capabilities |
| Power Supply | Adherence to voltage and current requirements | Stable power delivery for uninterrupted operation |
| Peripheral Devices | Interfacing compatibility | Harmonious operation with interconnected devices |
Furthermore, considerations extend beyond the individual components to encompass the broader ecosystem, encompassing factors such as form factor compatibility, mounting options, and environmental robustness. Through meticulous attention to detail and a comprehensive approach to integration, the hardware ensemble culminates in a cohesive unit, ready to navigate the complexities of its operational domain.